INTELLIGENCE
IN MOTION
Bridging cognitive machine learning with high-torque compliant mechanics. We build bipedal humanoids, agile quadrupeds, and sub-millimeter robotic manipulators designed to operate alongside humans safely in unpredictable real-world environments.
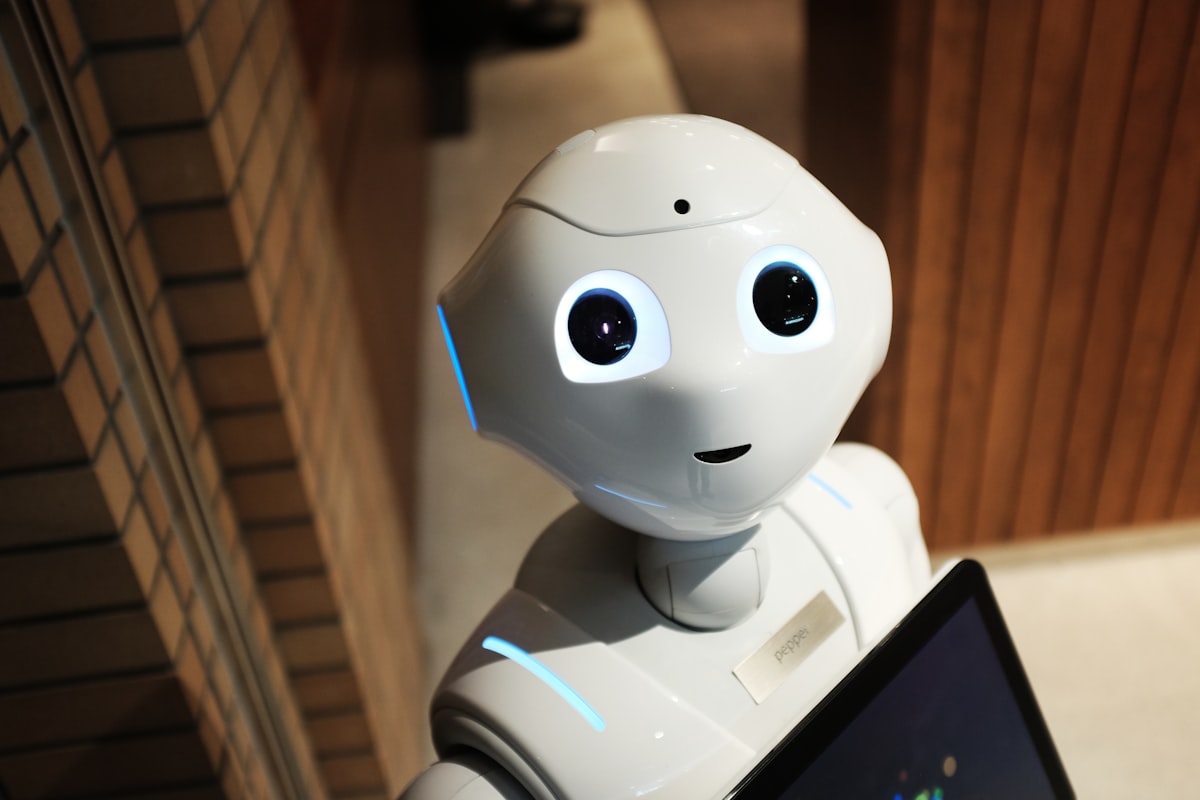
HARDWARE + SOFTWARE HARMONY
True physical robotics cannot be solved by software alone. We co-design electric motor windings, titanium-carbon skeletons, and custom neural silicon.
High-Torque Quasi-Direct Drives
Low-inertia planetary gearboxes paired with planar brushless motors provide transparent back-drivability. The robot can absorb high-energy shocks and feel external contact passively.
Multi-Spectral Solid-State SLAM
Combining 360-degree high-density solid-state LiDAR, dual 120 FPS event cameras, and tactical-grade IMUs to generate real-time metric occupancy grids without satellite connectivity.
Tactile-Array Dexterity
20-degree-of-freedom robotic hands embedded with micro-piezoelectric shear sensors capable of catching a fragile egg, threading needles, or wielding heavy construction wrenches.
ATLAS SYSTEM METRICS
Technical specifications of our latest autonomous humanoid chassis.
WHERE OUR ROBOTS OPERATE
Targeted mission profiles engineered for human safety and industrial resilience.

Search & Rescue
Navigating collapsed structures, toxic plumes, and extreme earthquakes where human first responders face lethal hazard.
Nuclear & Energy Inspection
Autonomous ultrasonic non-destructive testing inside active radiation vaults, high-voltage transformer yards, and pipelines.
Planetary & Lunar Proving
Regolith excavation, orbital solar array deployment, and radiation-shielded habitat assembly under vacuum conditions.

Precision Bio-Manipulation
Sub-micron tremor-canceled teleoperation aiding micro-vascular surgery and automated bio-reactor cellular culture sampling.